Imaging engineering
High-Speed Imaging
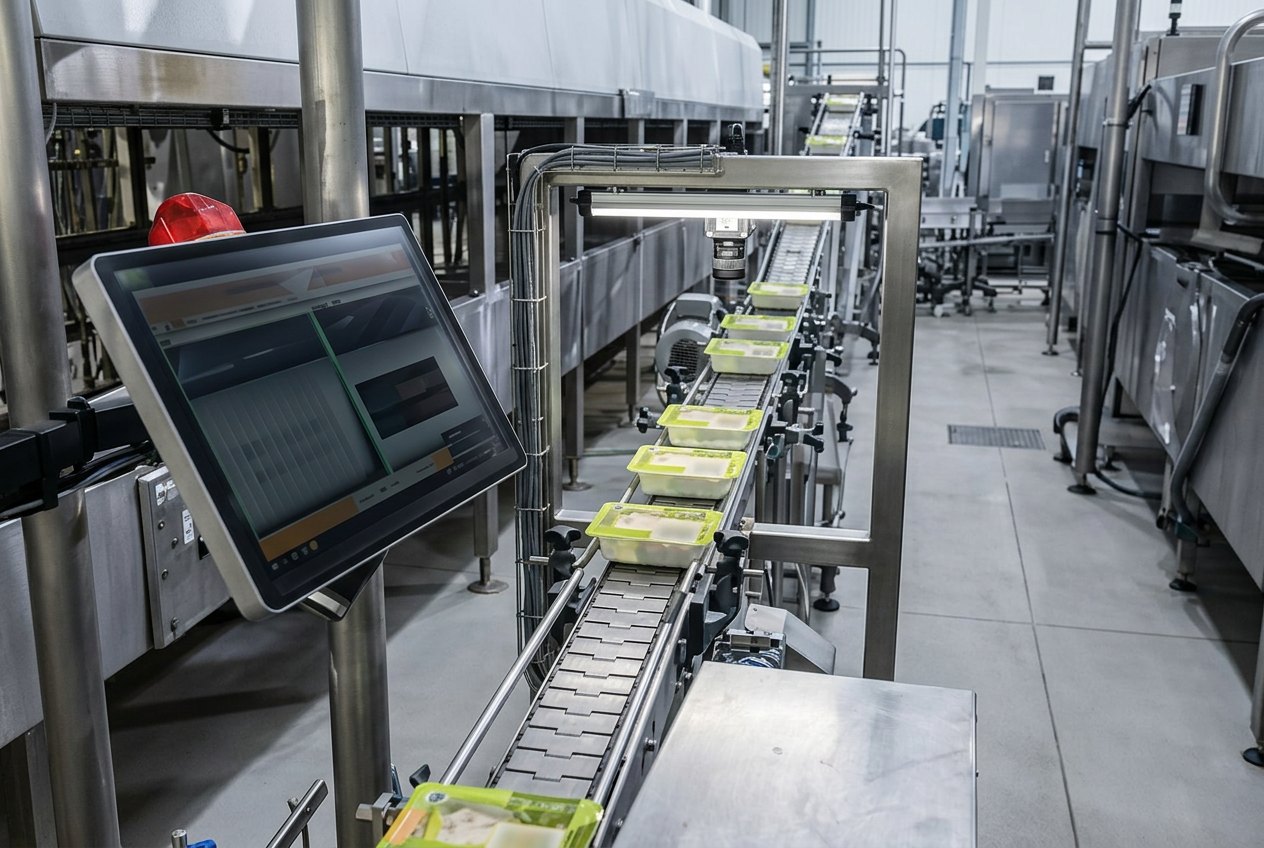
At speed, the constraints stop being software. Light, exposure, trigger jitter and bandwidth set the ceiling.
Direct answer
What limits high-speed machine vision inspection?
Four things: available light at very short exposures, sensor readout and interface bandwidth, trigger latency and jitter relative to part position, and the compute time available before the reject decision must be issued. Resolution and algorithm sophistication are usually traded away to satisfy those limits.
The four ceilings
- Photons
- Short exposure needs intense pulsed light and efficient optics
- Bandwidth
- Pixels × bit depth × rate × cameras vs interface envelope
- Timing
- Trigger jitter must be small relative to travel per pixel
- Decision window
- Time from image to verdict before the reject actuator
Fig. — Motion blur budget and the frozen-image condition
Exposure too long — smear > feature
Strobed short exposure — smear < ⅓ pixel
smear (mm) = v (mm/s) × texp (s) · target: smear ≤ ⅓ × pixel footprint on the part · light required scales as 1 ÷ texp
Techniques we rely on
- Global-shutter sensors with pulsed, overdriven illumination synchronized to the trigger.
- Region-of-interest readout to trade unused pixels for frame rate.
- Deterministic acquisition paths and buffering so frames are never dropped silently.
- Hardware triggering from encoder position rather than software polling.
- Parallel processing across cameras with a bounded worst-case decision time.
Honest limits
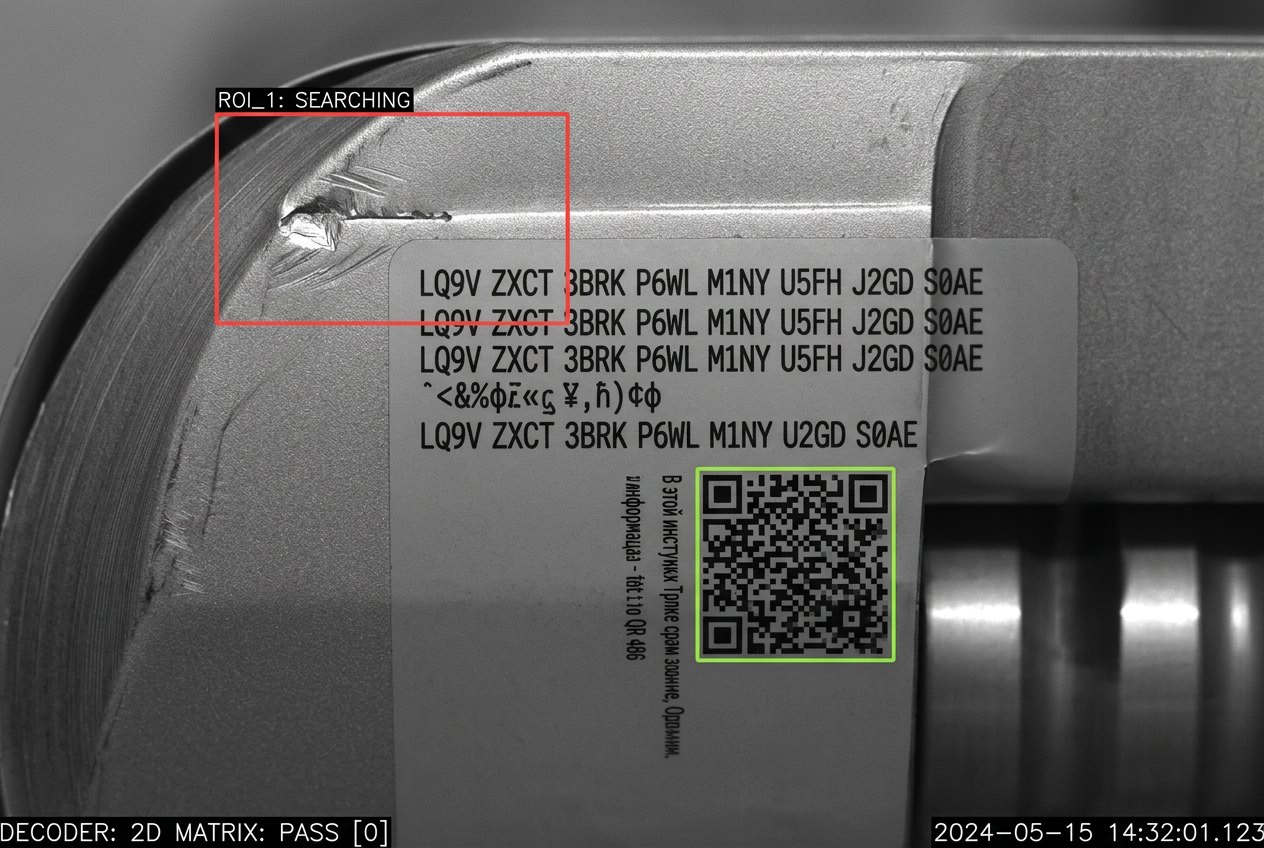
Some inspection tasks cannot be done at the requested line speed with acceptable false-reject rates. Saying so during feasibility is cheaper than discovering it during commissioning. Where the physics does not close, we propose alternatives: sampling strategies, slowing a single station, splitting lanes, or changing product presentation.
Related engineering material